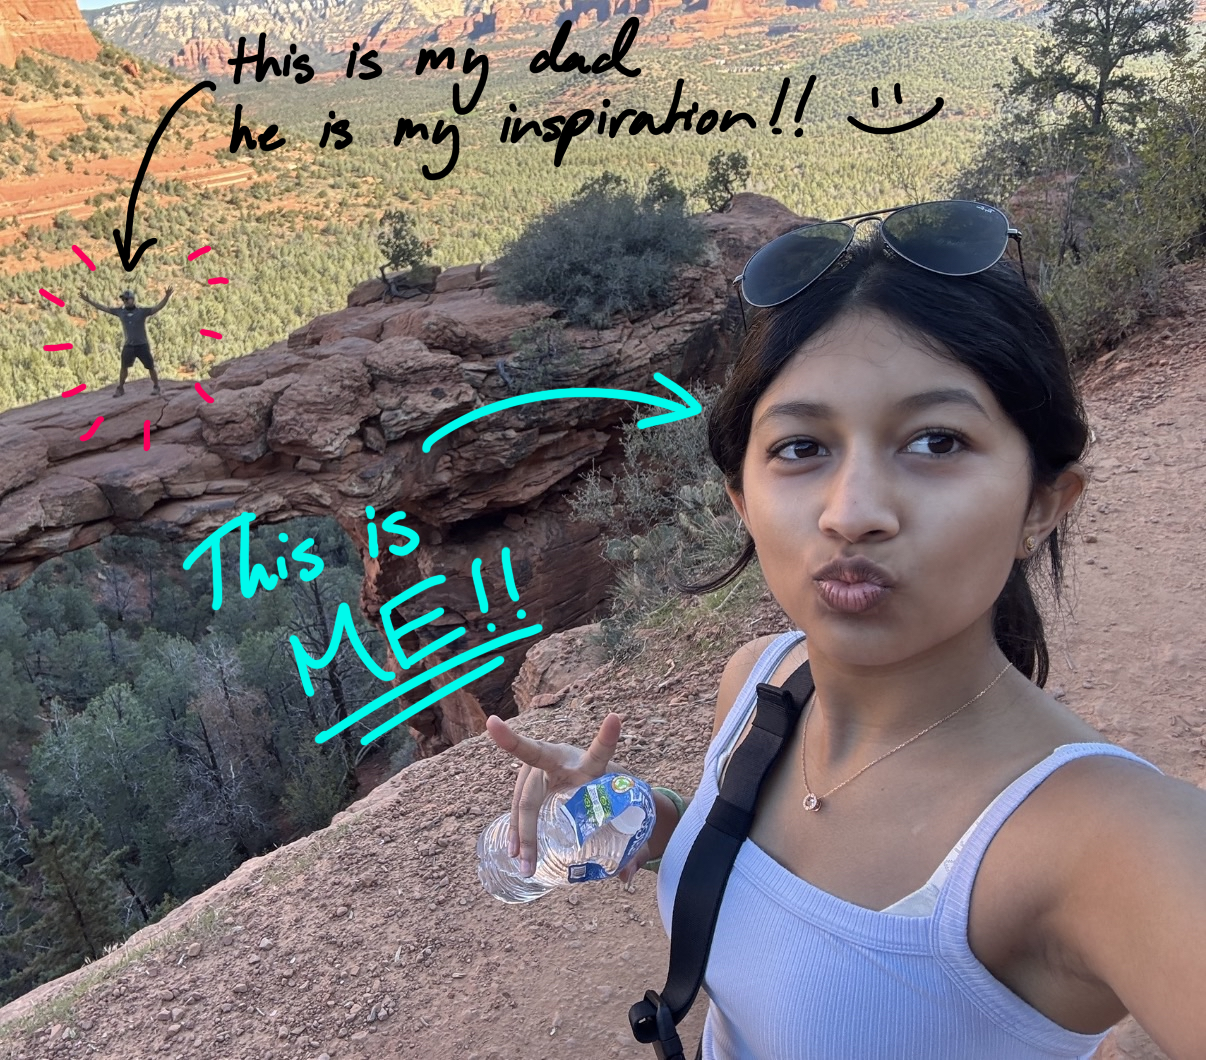
hey, it's kesia

i think robots are cool

~/kesia — zsh

~ $ whoami

kesia fernandes — B.S. Robotics Eng + Data Science, UCR '28

~ $ cat interests.txt

autonomous systems, computer vision, embedded systems, hardware-software integration

~ $

scroll

building the future,
one commit at a time.

I’m a robotics engineering student at UC Riverside with a minor in Data Science. I’m interested in intelligent systems and enjoy building software that brings machines to life in the real world.

Some of my experience includes building a vision-guided robotic arm using YOLOv8 and OpenCV, as well as implementing autonomous navigation behaviors in ROS2 simulations. Right now I’m focused on learning the fundamentals of ROS2 and improving my Python skills by playing around in Gazebo.

Outside of robotics, I enjoy playing FPS games, reading manga, hiking, and doing anything that lets me indulge my creativity. I love to make stuff!!!!!

3.72
GPA
UCR
class of '28
2+
yrs robotics
kesia
UCR // robotics eng '28

my tech arsenal

// languages & robotics

Python familiar
C++ proficient
ROS 2 learning
OpenCV / YOLOv8 familiar
Java / JavaScript proficient

// hardware & tooling

Arduino / Raspberry Pi learning
SolidWorks / CAD proficient
Git / GitHub / Linux proficient
pandas / NumPy familiar
GoogleTest / Valgrind / PyTest familiar
Python C++ Java JavaScript ROS2 OpenCV YOLOv8 Arduino Raspberry Pi SolidWorks pandas NumPy GoogleTest Valgrind Git / GitHub Linux / Ubuntu Azure DevOps Agile / Scrum

roles & experience

Software Developer
ACM Forge — Association for Computing Machinery, UC Riverside
Mar 2025 – Jun 2025
Riverside, CA
  • Built and deployed a Python-based robotic arm system integrating computer vision and serial communication to control physical hardware in real time.
  • Optimized the vision pipeline via multithreading, cutting system latency by 30% on resource-constrained Raspberry Pi hardware.
  • Collaborated hands-on with mechanical and electrical subteams to integrate, validate, and iterate on autonomous control systems through multiple test cycles.
Python OpenCV Raspberry Pi Multithreading
Technical Documentation Lead
VEX Robotics — Competitive Robotics Team
Jun 2022 – Apr 2024
Fremont, CA
  • Authored engineering notebooks and SolidWorks CAD documentation covering hardware schematics, design iterations, and validation procedures across multiple build cycles.
  • Coordinated software, mechanical, and manufacturing subteams to align design iteration, testing, and competition deliverables on tight timelines.
SolidWorks CAD Technical Writing
Robotics Instructor (Volunteer)
Friends of Children with Special Needs — FCSN Youth Program
Jun 2022 – Jun 2024
San Jose, CA
  • Designed and delivered hands-on robotics curriculum using LEGO WeDo and Scratch for students with special needs.
  • Created sensor-based and event-driven programming lessons, improving student engagement and foundational CS comprehension.
LEGO WeDo Scratch Curriculum Design

some of my work

EdgeVision Walking Aid
edge ai · assistive tech

EdgeVision Walking Aid

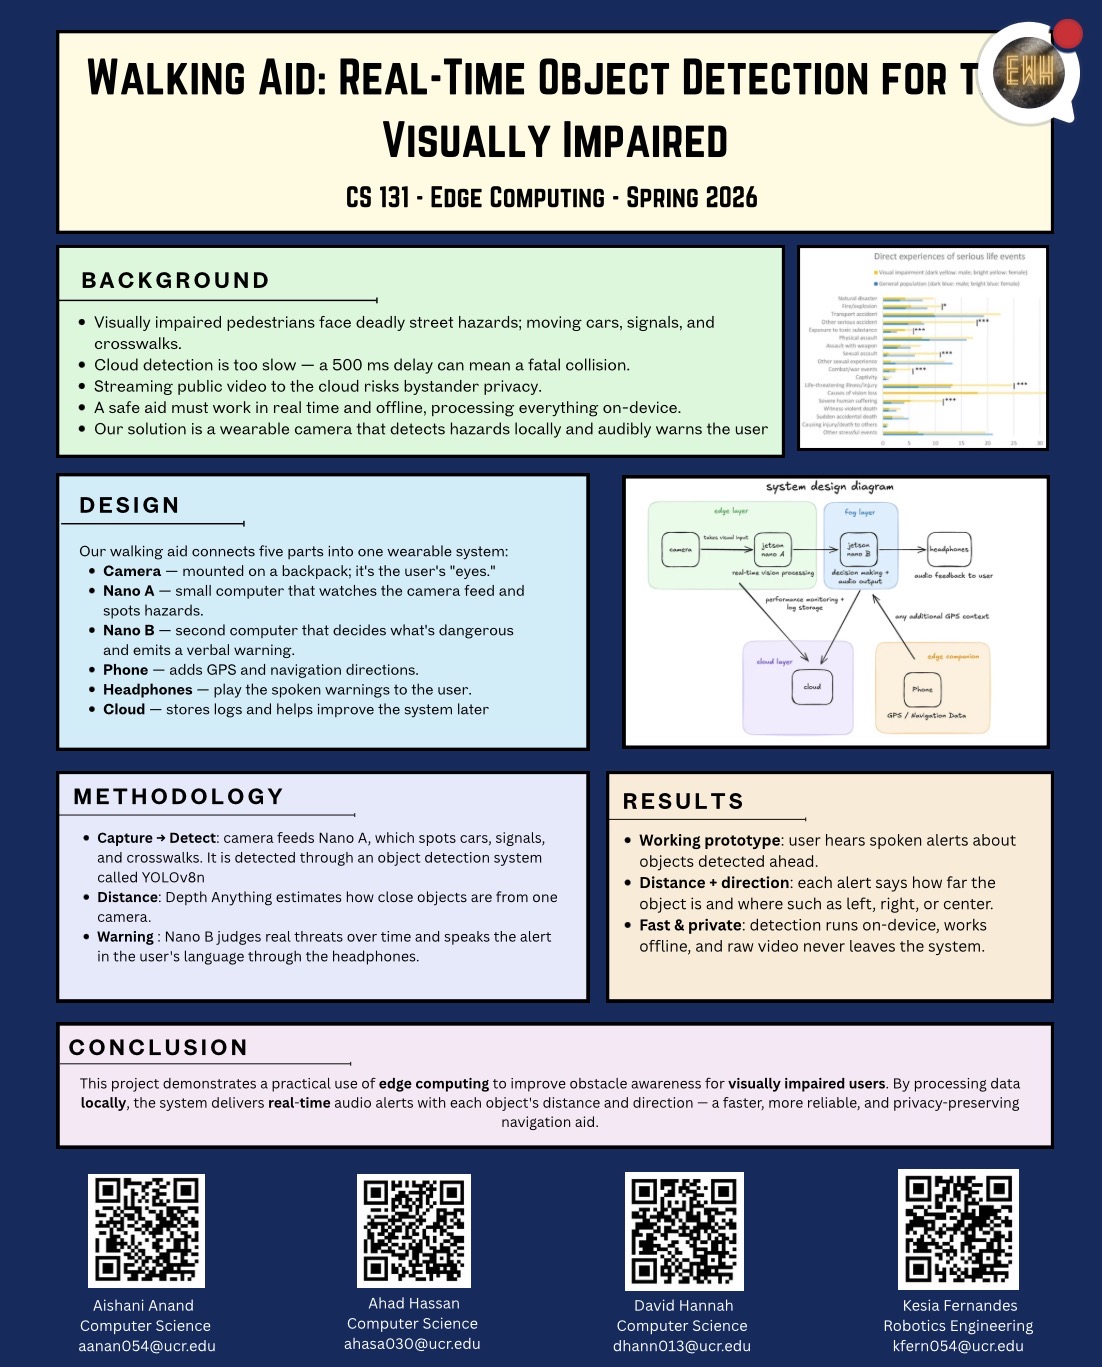
Led a 4-person team to build a distributed hazard-detection system across two Jetson Nanos. Integrated Depth Anything V2 with YOLOv8n for monocular distance estimation and built a 30 FPS pipeline with TTS output and priority-queue deduplication.

Python YOLOv8n Depth Anything V2 Jetson Orin Nano
Autonomous Robotic Arm
computer vision

autonomous robotic arm

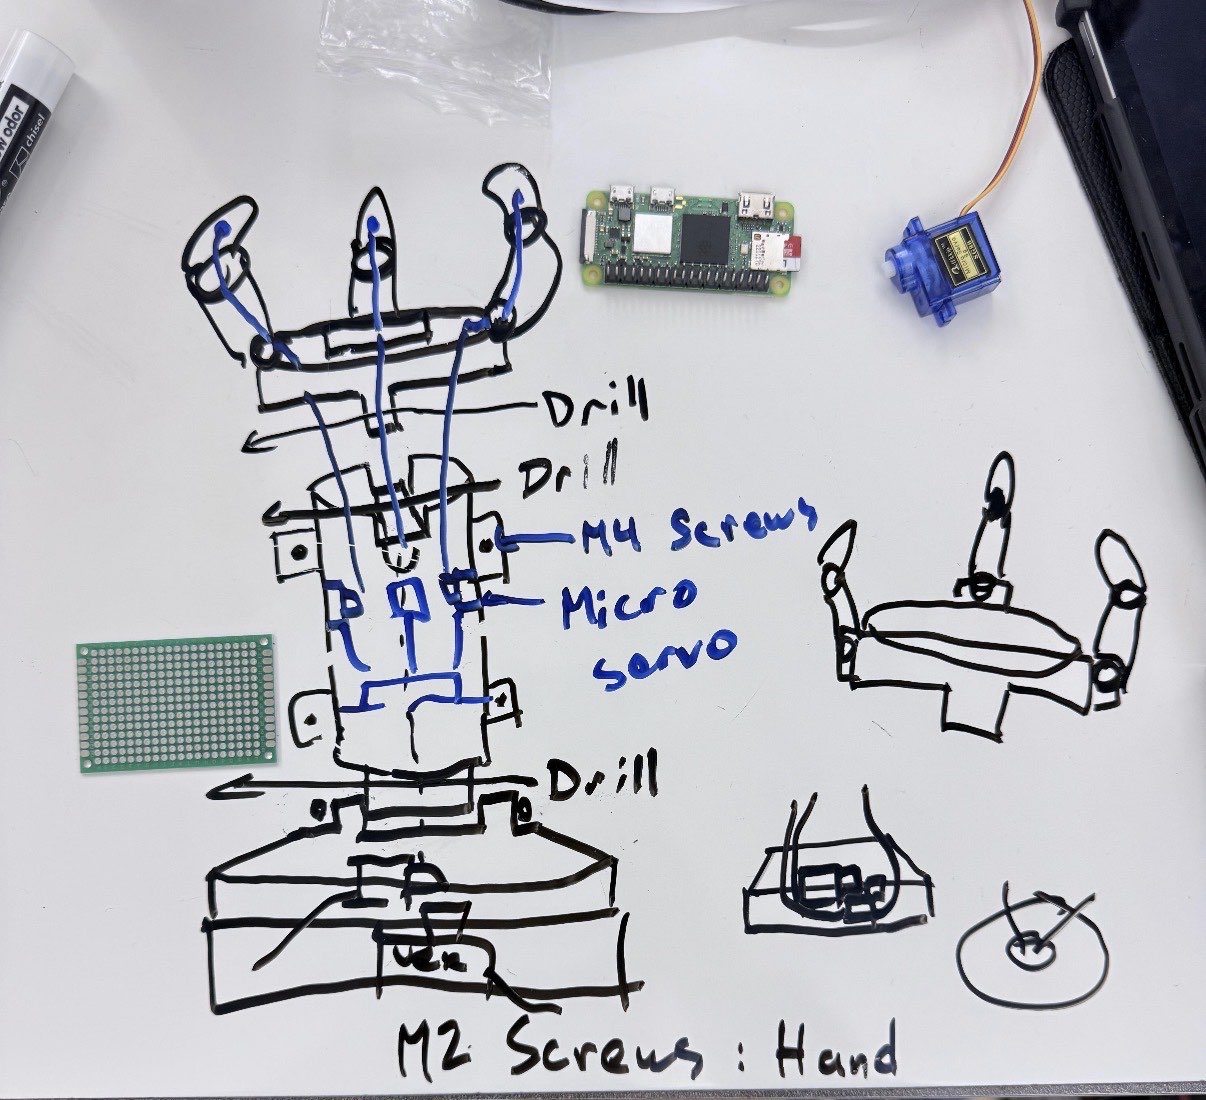
Built and deployed a vision-guided robotic arm using YOLOv8 and OpenCV for real-time object detection and physical manipulation. Collaborated with mechanical and electrical engineers on CAD design and hardware integration.

Python YOLOv8 OpenCV Raspberry Pi Arduino
Autonomous Robot Navigation
autonomous navigation

autonomous robot navigation

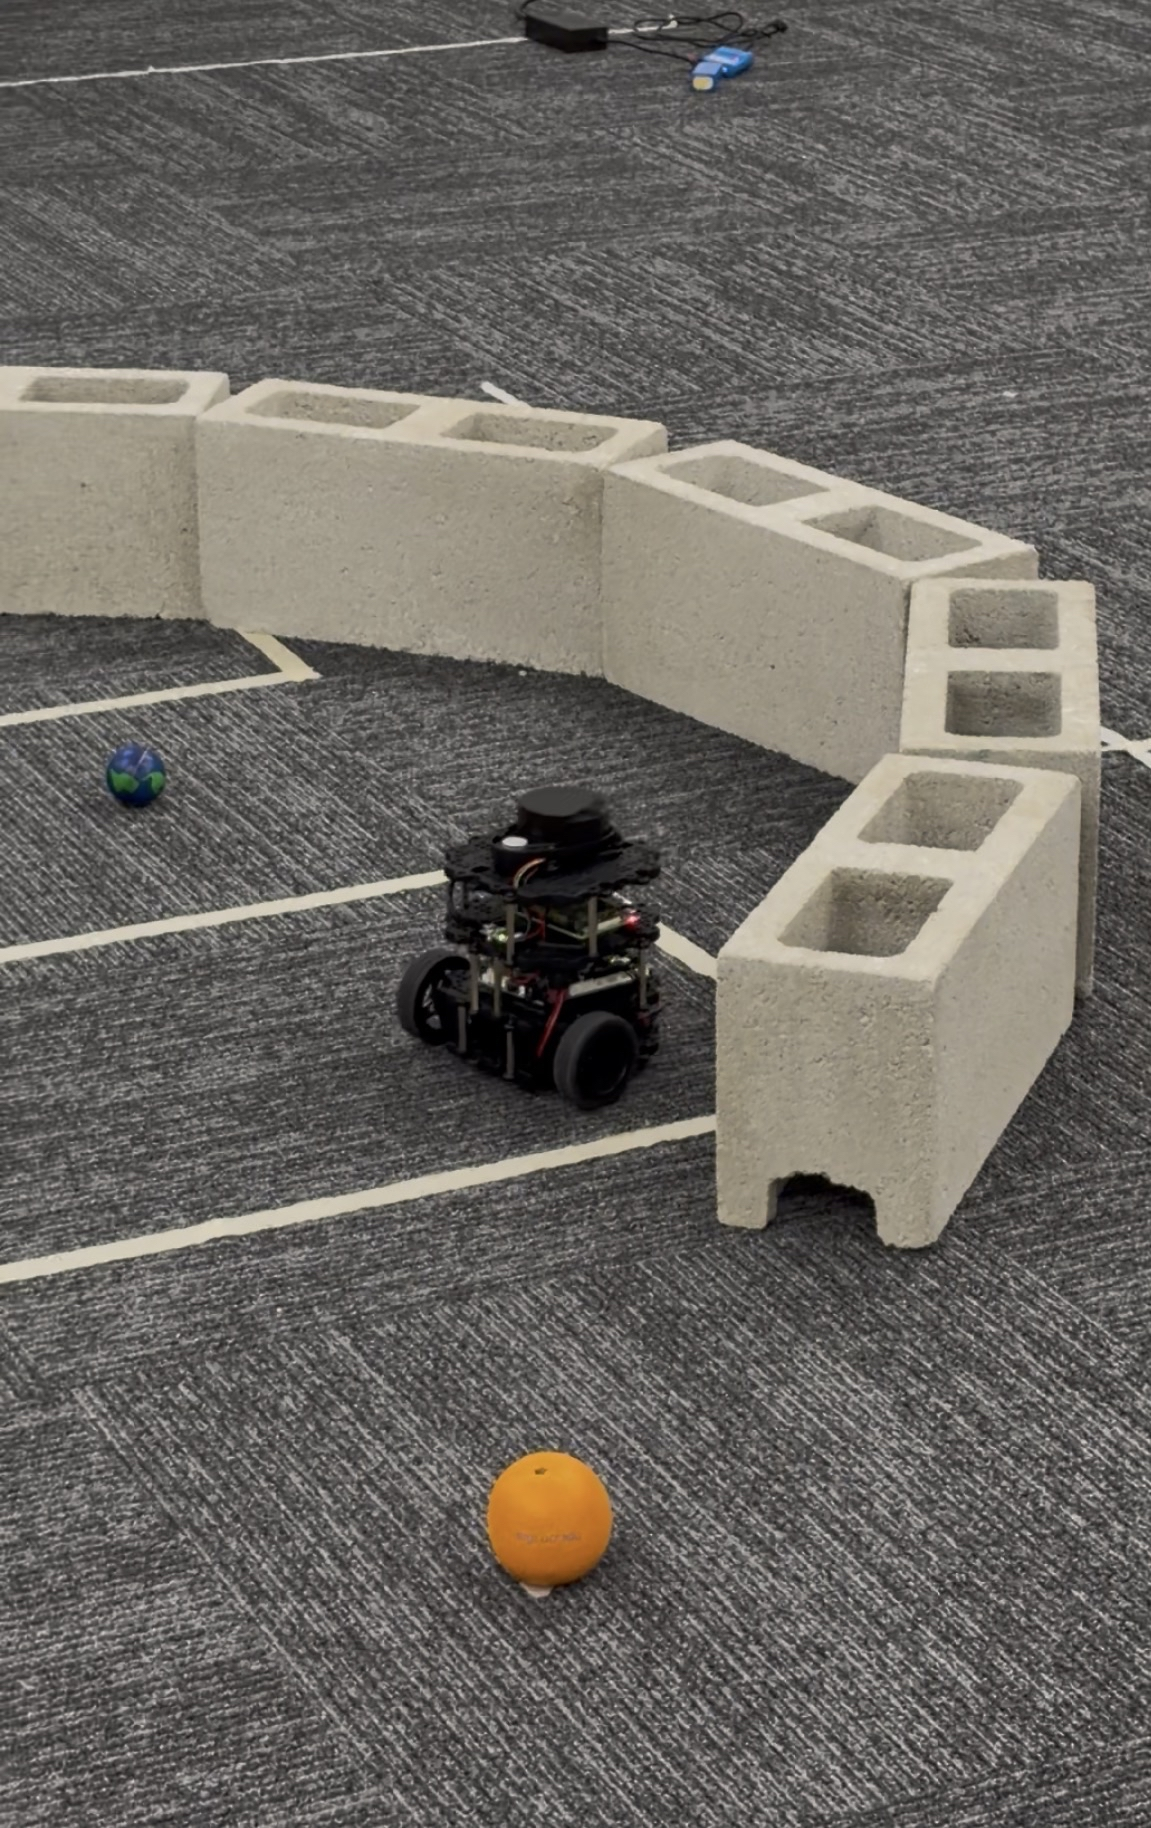
Implemented wall-following and trajectory generation behaviors for a simulated robot using ROS2 nodes, topics, and publishers/subscribers in a Linux environment. Building familiarity with autonomous navigation stacks and sensor integration.

ROS 2 Python Linux / Ubuntu
Text-Based Mystery RPG
software engineering

text-based mystery RPG

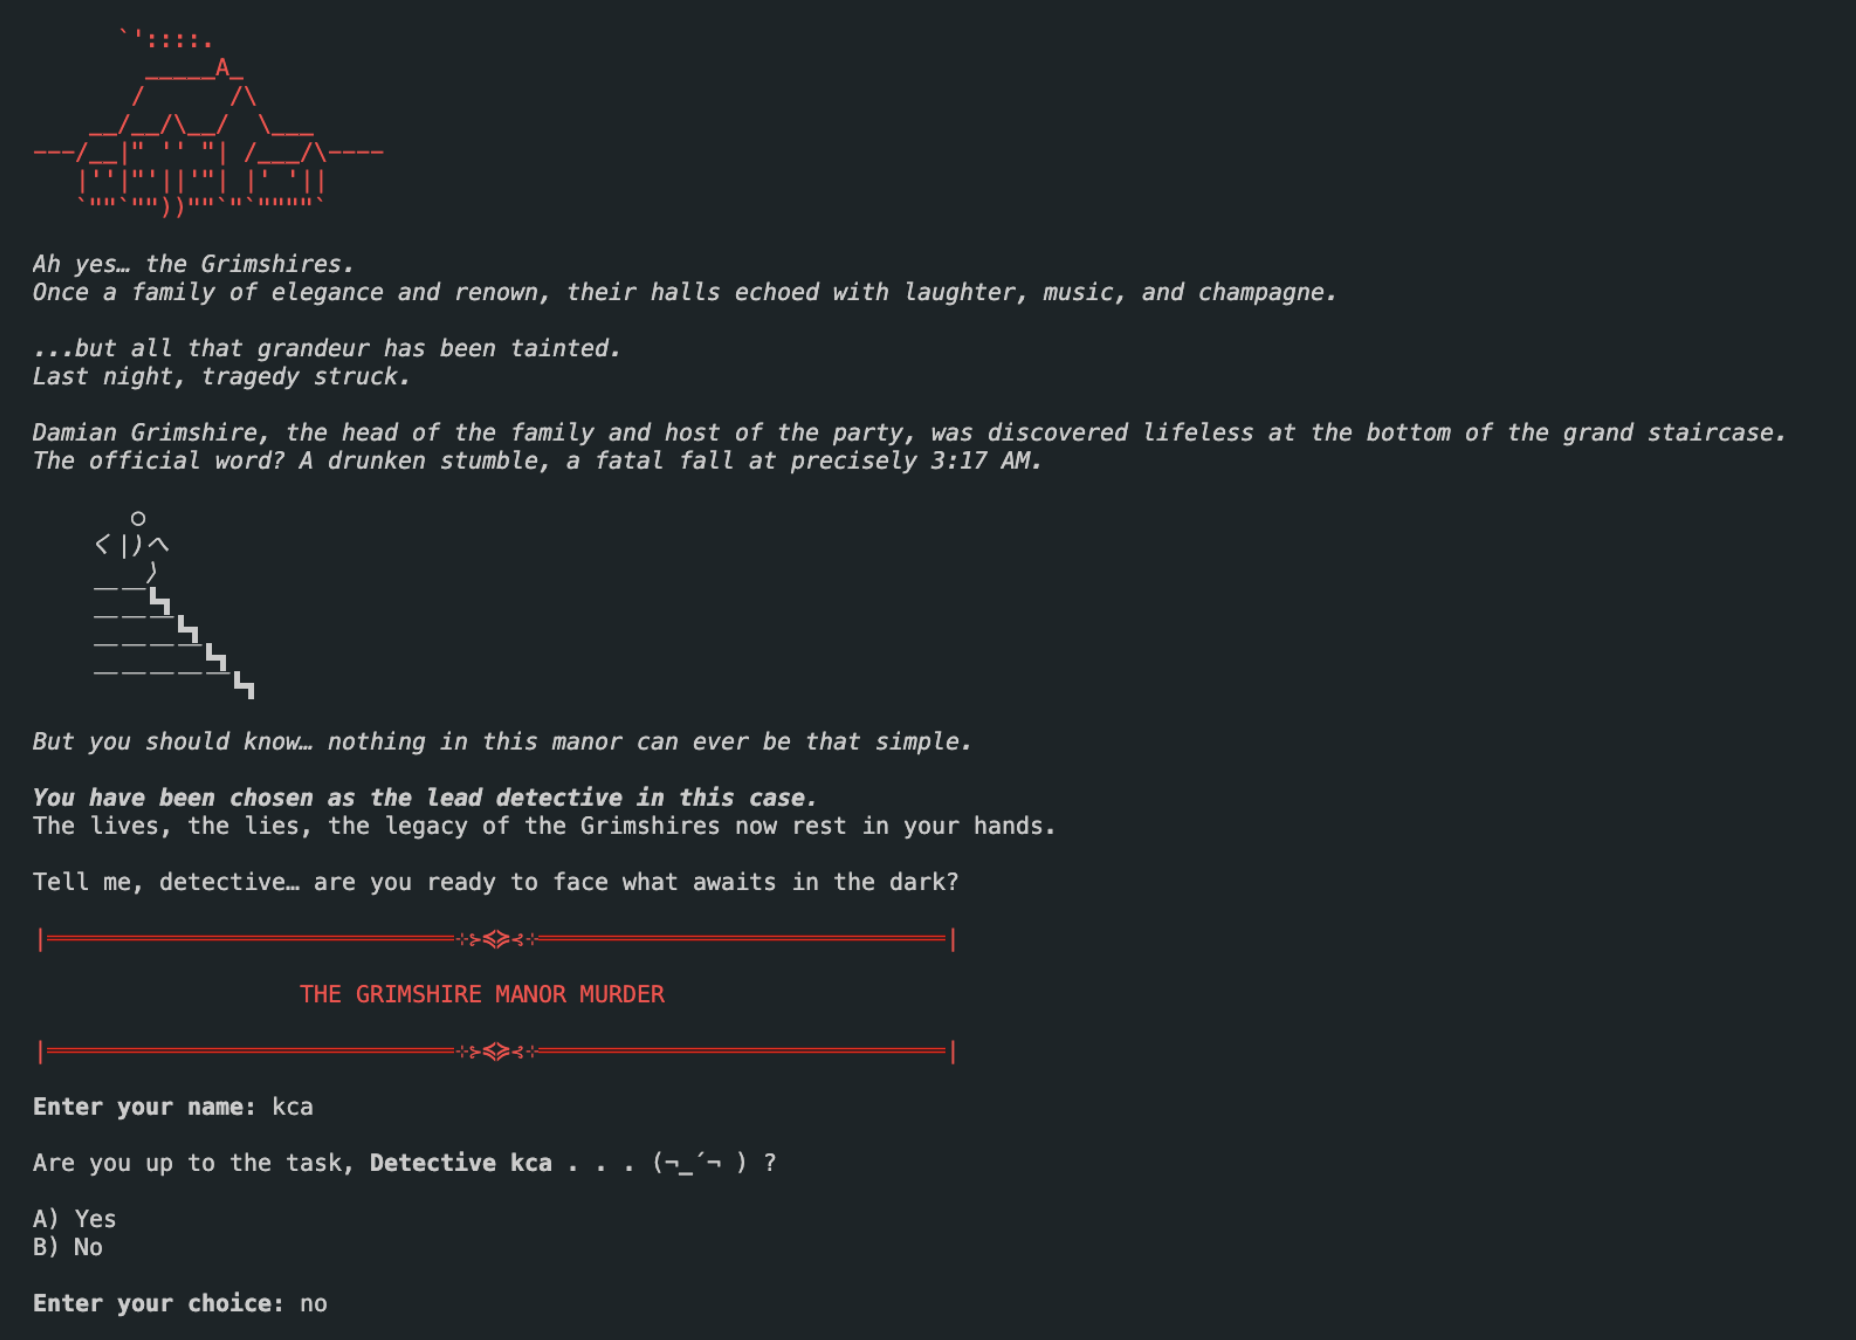
Architected a C++ mystery game using OOP and SOLID principles. Validated correctness and eliminated memory leaks using GoogleTest and Valgrind.

C++ OOP / SOLID GoogleTest Valgrind

let's build something
together.

open to internships, research, and interesting side projects.
if you're working on something cool, let me know!

contact.sh
github: @kcafernandes
linkedin: /kesia-fernandes
phone: 510-770-4087
send a message →